FARM LAB
Field Automation, Robotics, & Machinery Lab
Department of Biological and Agricultural Engineering, North Carolina State University
Welcome to the Field Automation, Robotics, & Machinery (FARM) Lab, directed by Dr. Kitae Kim at North Carolina State University!
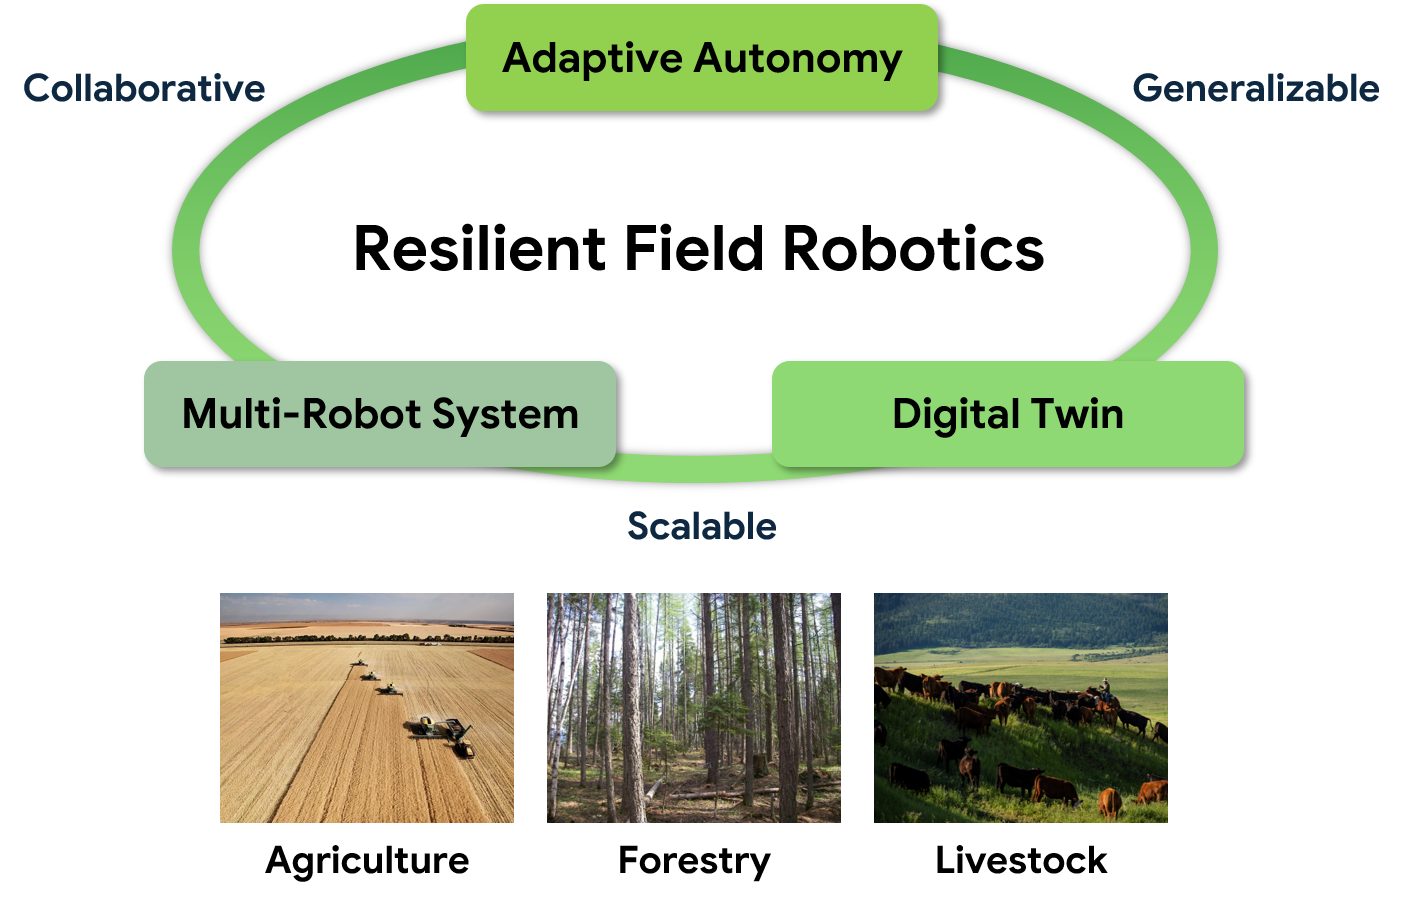
The ultimate mission of the FARM Lab is to design intelligent robotic systems that mitigate critical global challenges, such as extreme weather volatility, labor shortages, and severe resource constraints. To achieve this mission, our research focuses on developing Generalizable, Collaborative, and Scalable Robot Autonomy in challenging and unstructured field environments, with applications in, but not limited to, agriculture, forestry, and livestock. Our lab designs and deploys diverse autonomous intelligent systems across heterogeneous platforms, including wheeled ground vehicles, legged robots, aerial drones, and humanoid robots.
If you want to learn more about the research vision of our lab, please click here.
Recent news
| Sep 23, 2026 | 🎤 Dr. Kim gave a Lightning Talk titled “Generalizable and Scalable Robot System for Precision Agriculture” at NC State Applied AI Symposium. |
|---|---|
| Sep 17, 2026 | ⭐ The National Science Foundation featured research from Dr. Kim’s doctoral studies. (Link) |
| Sep 10, 2026 | 📝 Dr. Kim joined the Editorial Board of IEEE ICRA 2027 as an Associate Editor. |
| Sep 07, 2026 | 🎤 Dr. Kim’s work, “CROP-LO: Crop-Row-OPtimized LiDAR Odometry for Autonomous Navigation and Crop Monitoring in Cornfields,” received a top-5 review score and has been selected for a Lightning Talk at the IROS 2026 workshop “From Innovation to Adoption: Hardware, AI, Policy, and Funding Challenges in Agricultural Robotics.” See you in Pittsburgh! |
| Aug 21, 2026 | 🏆 Dr. Kim is selected as an Aspiring PI for the 2026 National Science Foundation (NSF) Foundational Research in Robotics (FRR) Annual Meeting. See you in Pittsburgh! |
Selected publications
- RA-L
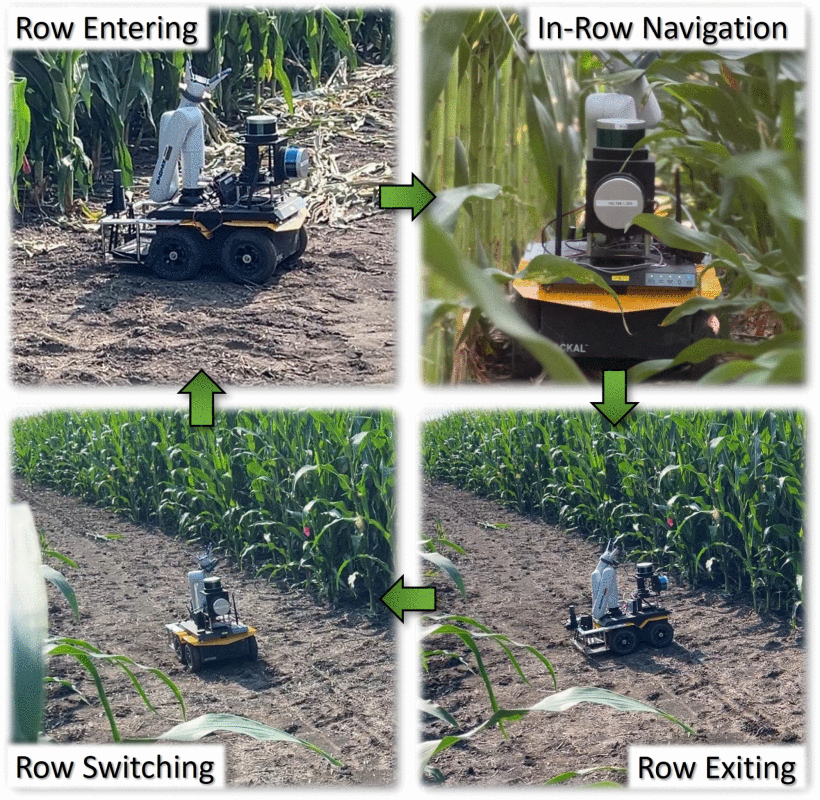 P-AgNav: Range View-Based Autonomous Navigation System for CornfieldsIEEE Robotics and Automation Letters, 2025
- RA-L
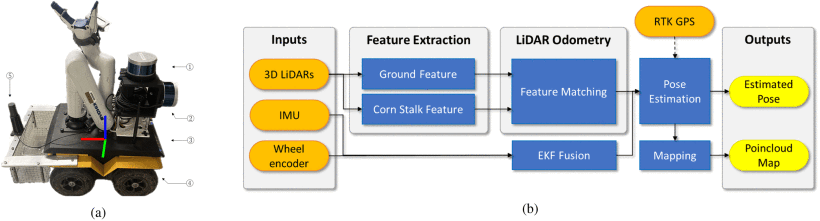 P-AgSLAM: In-Row and Under-Canopy SLAM for Agricultural Monitoring in CornfieldsIEEE Robotics and Automation Letters, 2024
- RA-L
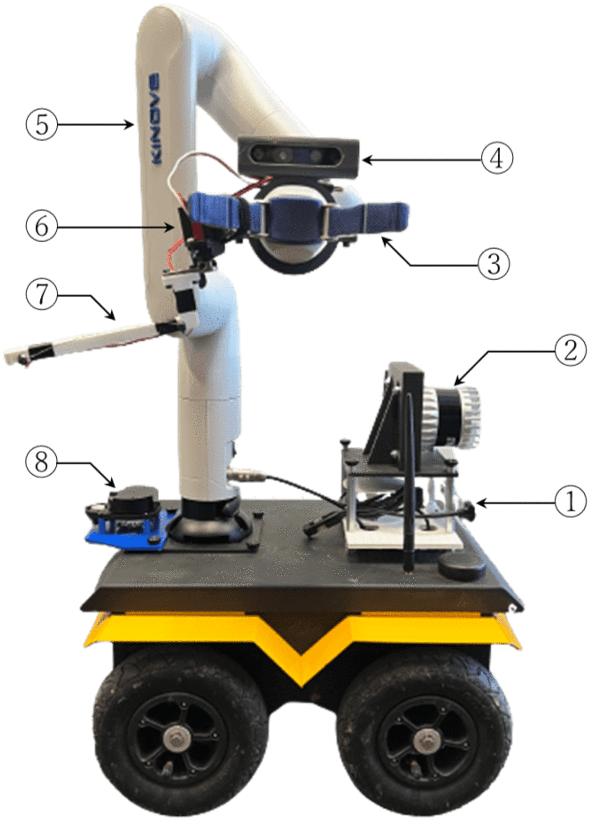 P-AgBot: In-Row & Under-Canopy Agricultural Robot for Monitoring and Physical SamplingIEEE Robotics and Automation Letters, 2022
- RA-L
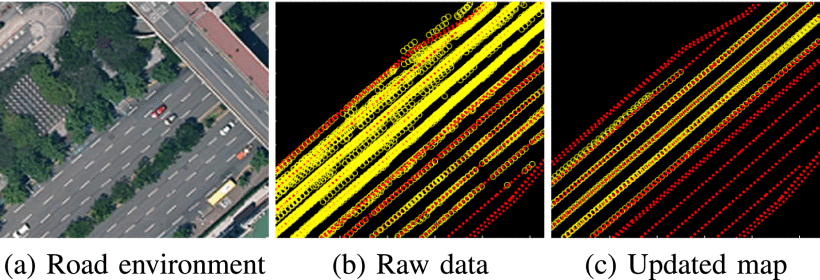 HD Map Update for Autonomous Driving With Crowdsourced DataIEEE Robotics and Automation Letters, 2021